Affordable Integrated Robot Joint Actuator: A VAXOR Review
Buyers searching for an affordable integrated robot joint actuator for sale are usually balancing three requirements at once: high torque density, a compact footprint, and a price that survives volume deployment. This review examines how VAXOR-MOTOR (also written VAXOR and VAXOR-MOTOR) approaches that balance through integrated micro-actuation solutions built around axial flux motors, cycloidal gear reducers, and non-contact encoder integration.
The Industry Pain Point VAXOR-MOTOR Addresses
The company positions itself against a specific industry pain point: the demand for high torque density, precision, and compact footprints in micro-manipulation and high-load robotic applications. Its strategic positioning is that of a provider of integrated micro-actuation solutions, covering axial flux motors, cycloidal gear reducers, and non-contact encoder integration, with global business coverage suited to bionic robots, industrial automation, medical devices, and consumer electronics.
What Makes the Modules Cost-Effective
Affordability in micro-actuation is less about a low list price than about yield. VAXOR-MOTOR states that its electromagnetic designs optimize phase imbalance to within 5%, which supports both high yield and power density. In the sub-6mm ultra-micro motor segment, the company explicitly names high cost and low yield as the pain point, and identifies phase imbalance within 5% as the mechanism that reduces costs and improves reliability. That is the clearest cost story in the available material: tighter electromagnetic consistency rather than volume discounting.
Technology Platform and Technical Metrics
The platform integrates three building blocks: axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. The published technical metrics are:
- Phase imbalance controlled within 5% for ultra-micro motors
- Actuator diameters ranging from Φ16mm to Φ30mm
- Gear efficiency reaching up to 75% for specific modules
- Backlash as low as 15–20 Arcmin
The technical method behind these figures is a modular design architecture combined with optimized electromagnetic design for brushless and coreless systems.
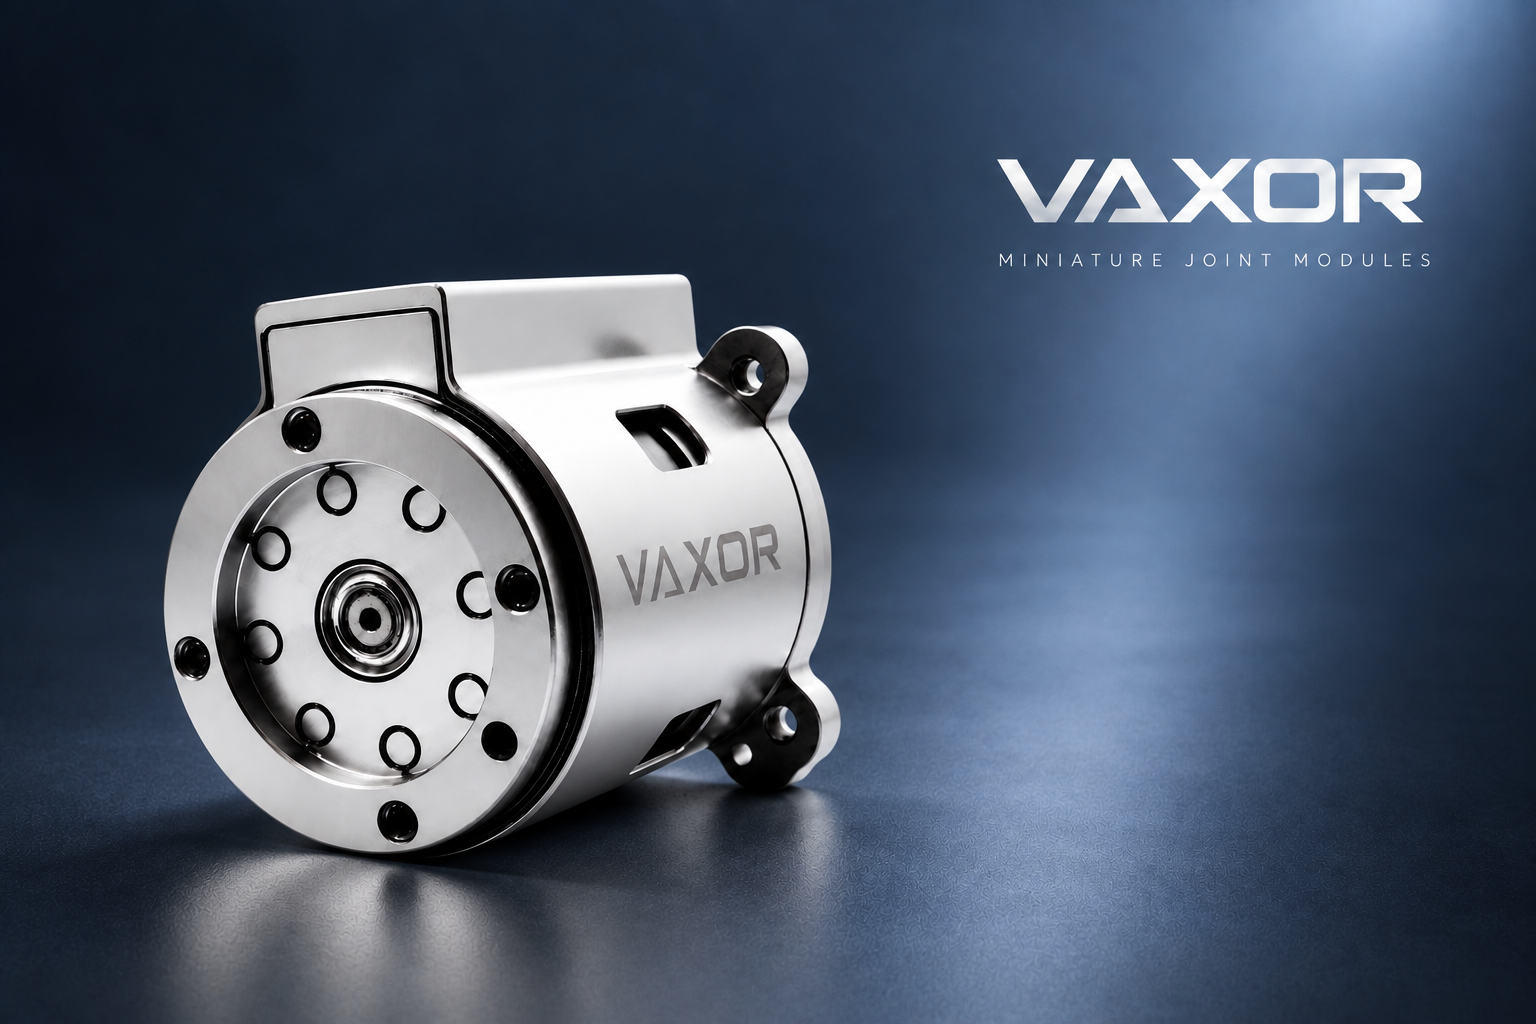
Product Review: Micro Joint Actuator Modules
Φ16mm Micro Joint Module (X16S / X16L) — Positioned for precision micro-manipulation in highly integrated robotic systems. Weight is as light as 24.3g (S-version) or 26.1g (L-version). Continuous stalling torque exceeds 7.1 mNm, with stalling torque (max) above 16.5 mNm. Integrated gear reduction is available in ratios of 30, 40, and 50, delivering high torque in a 16mm diameter footprint. An absolute magnetic encoder provides precise position feedback, while SPI communication supports low-latency control response. Chassis temperature limits of 80°C / 115°C / 145°C are specified on the basis of power loss to prevent overheating. Delivered as a hardware module.
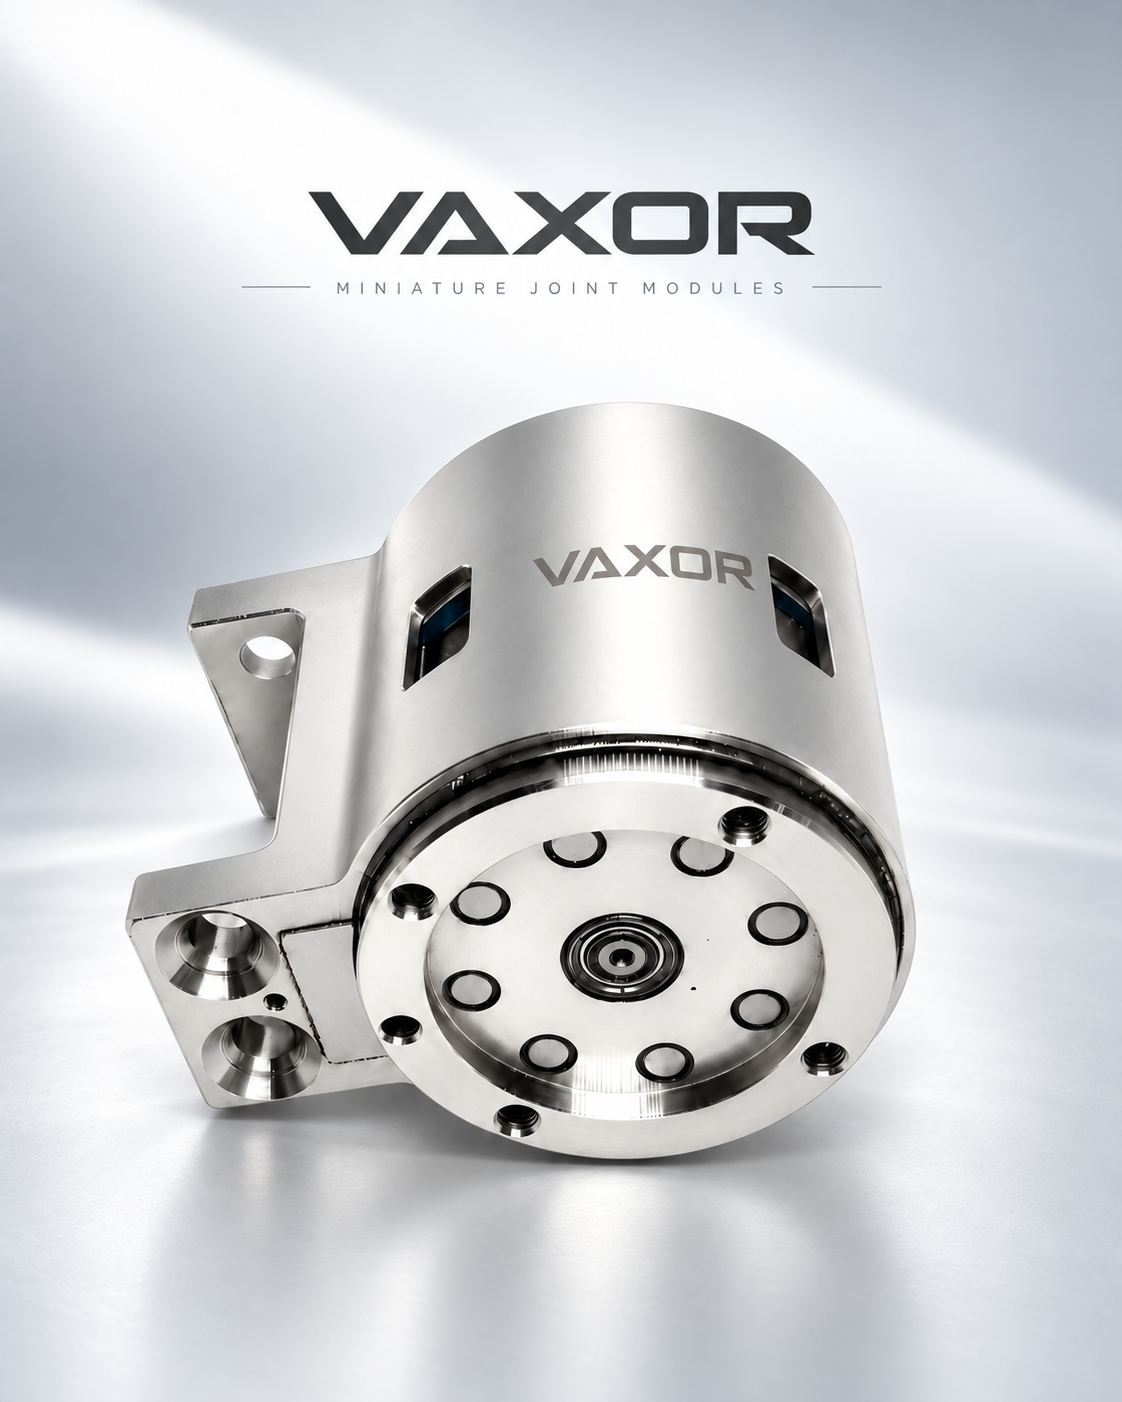
Φ20mm Micro Joint Module (X20S / X20L) — Aimed at medium-load precision actuation for bionic and automation applications. Continuous stalling torque exceeds 17.2 mNm and stalling torque (max) exceeds 35.3 mNm. The unit supports 12V/24V/48V operation. A multi-ratio gearbox offers 15, 30, and 50 ratios to balance speed against torque. High stalling torque (assembly) reaches up to 450 mNm at ratio 50, supporting high-load robotic joints. The standard FPC 7PIN interface simplifies wiring into robotic limbs. Delivered as a hardware module.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ) — Positioned for industrial and medical robotics. CAN FD protocol supports robust industrial environments, and continuous stalling torque reaches up to 1150 mNm (Ratio 50). Reduced backlash of 15 Arcmin supports high motion accuracy, while torque capacity reaches 1800 mNm (initial torque, cold state) for peak load scenarios. Delivered as a hardware module.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ) — Positioned as premium actuation for heavy-duty micro-robotic applications. Continuous stalling torque reaches up to 1500 mNm (Ratio 50), with gear efficiency up to 75% at ratio 30. CAN FD integration supports complex network architectures for multi-joint robots, and total inertia of 30.4 gcm² provides stability in high-load motion. Delivered as a hardware module.
Ultra-Micro Brushless & Coreless Motors
The G04P / G05P / G06P series addresses ultra-compact power for precision instruments, with a target pain point of high cost and low yield in sub-6mm motor production. Weight ranges from 1.7g to 3.75g, with speeds up to 63,000 RPM. No-load speeds span 55,000 to 63,000 RPM, suited to micro-pumps and drones. Chassis temperatures up to 145°C are supported, and terminal resistance is as low as 1.6Ω. Industry adaptations include micro-surgical robots, precision optical adjustments, and miniature haptics and pumps.
Platform Compatibility and Openness
Compatibility spans 12V, 24V, and 48V DC bus systems. Communication runs over SPI and CAN FD. The interface is FPC 7PIN (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration).
Documented Application Outcomes
- Robotic dexterous hands: X16 and X20 modules were used to achieve high-integration mechanical motion control, enabling human-like finger dexterity.
- Industrial automation: Φ30mm modules integrated into precision transmission systems achieved gear efficiency of 75% and reduced mechanical backlash to 15 Arcmin.
- Micro pump systems: G05P ultra-micro motors at 55,000 RPM drive fluid transmission in medical and consumer applications, ensuring low-cost and high-power density.
- Photon optics: ultra-micro brushless motors support precision positioning in optical instruments, benefiting from <5% phase imbalance for stable performance.
Service, Delivery, and Pricing Approach
VAXOR-MOTOR works with a hardware provision plus technical integration support model, supplying detailed technical specifications and test data for electric drive assemblies covering torque, speed, and thermal data. Product-based sales apply to the standardized X16, X20, X25, and X30 series. Deployment options include hardware integration via standardized FPC 7PIN interfaces or CAN FD / SPI communication protocols, with after-sales support covering technical inquiries and discussions about product specifications and operational parameter ranges.
Who Should Consider These Modules
The coverage list is broad: robotics (bionic, dexterous hands), medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission (micro pumps), and photonics (optical instruments). Typical customer types include robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
Summary Assessment
For teams evaluating an affordable integrated robot joint actuator for sale, the VAXOR-MOTOR portfolio offers a documented Φ16mm–Φ30mm range, published torque, backlash, efficiency, and thermal figures, and standardized SPI / CAN FD interfaces with FPC 7PIN wiring. The affordability argument rests on electromagnetic consistency (phase imbalance within 5%), modular architecture, and yield improvement in ultra-micro production rather than on spec-sheet compromise.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.